Carnegie Mellon University
M.S. Mechanical Engineering - Advanced Study in Robotic and Control Systems
Expected December 2026Designing and building
mechatronic systems.
Precision systems · Robotic manipulators · Motion control
I combine mechanical design, sensing, and control to develop precision hardware, robotic mechanisms, and automated equipment.
M.S. Mechanical Engineering - Advanced Study in Robotic and Control Systems
Expected December 2026
B.S.E. Mechanical Engineering
Electrical Engineering minor
Mechatronic Engineering Intern
Electromagnetic modeling · Control-loop optimization
Robotics Intern
Robotic manipulators · Autonomous mobile base
Teaching Assistant
ALD equipment · Process automation
Mechanical Design Intern
Dynamic modeling · Motion control
Product Development Intern
Medical robotic packaging · Prototype development
 01
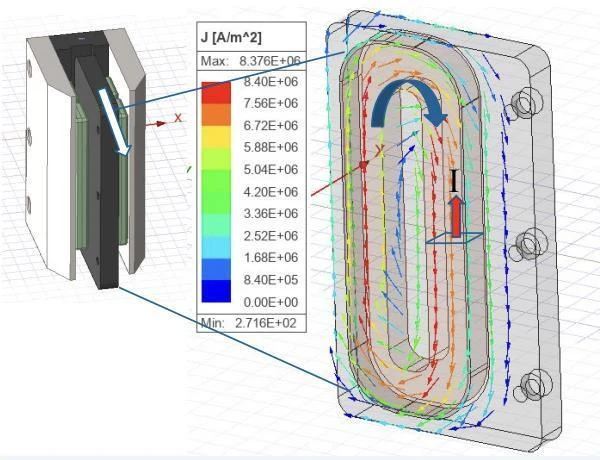
Predicting and mitigating eddy-current effects in precision actuators.
My contributionAnalytical and FEA models, geometry studies, and mitigation tools.
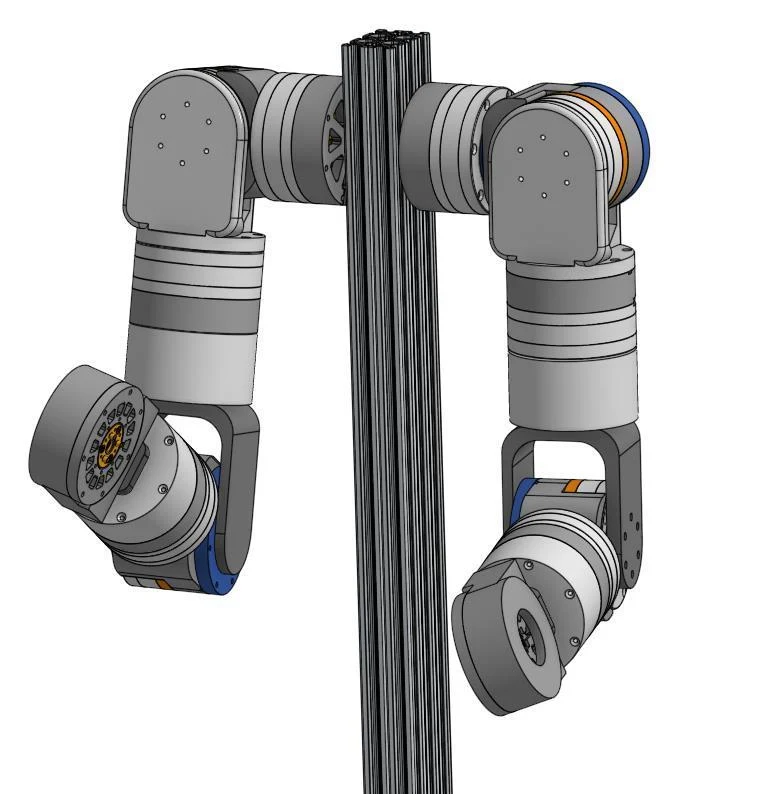
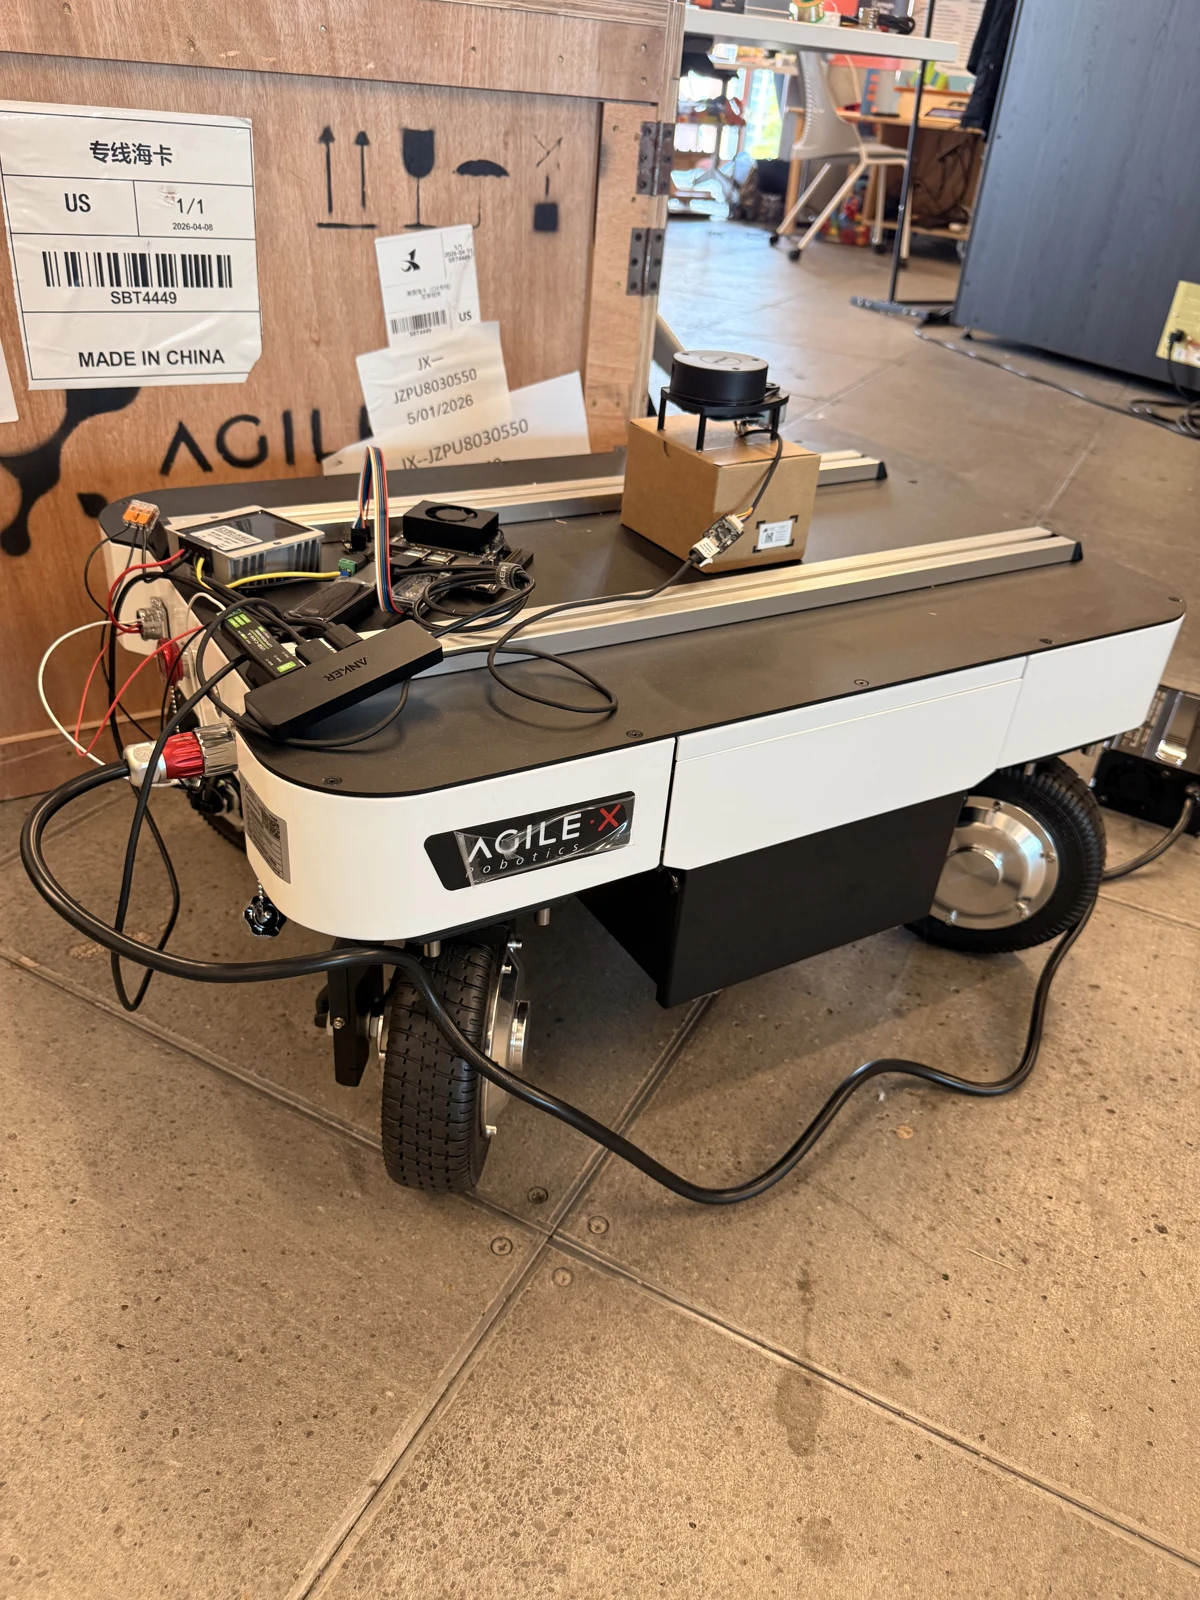
A modular 6-DOF arm, custom transmission, and mobile ROS2 platform.
My contributionArm design and fabrication, gearbox development, and mobile-base integration.
 03
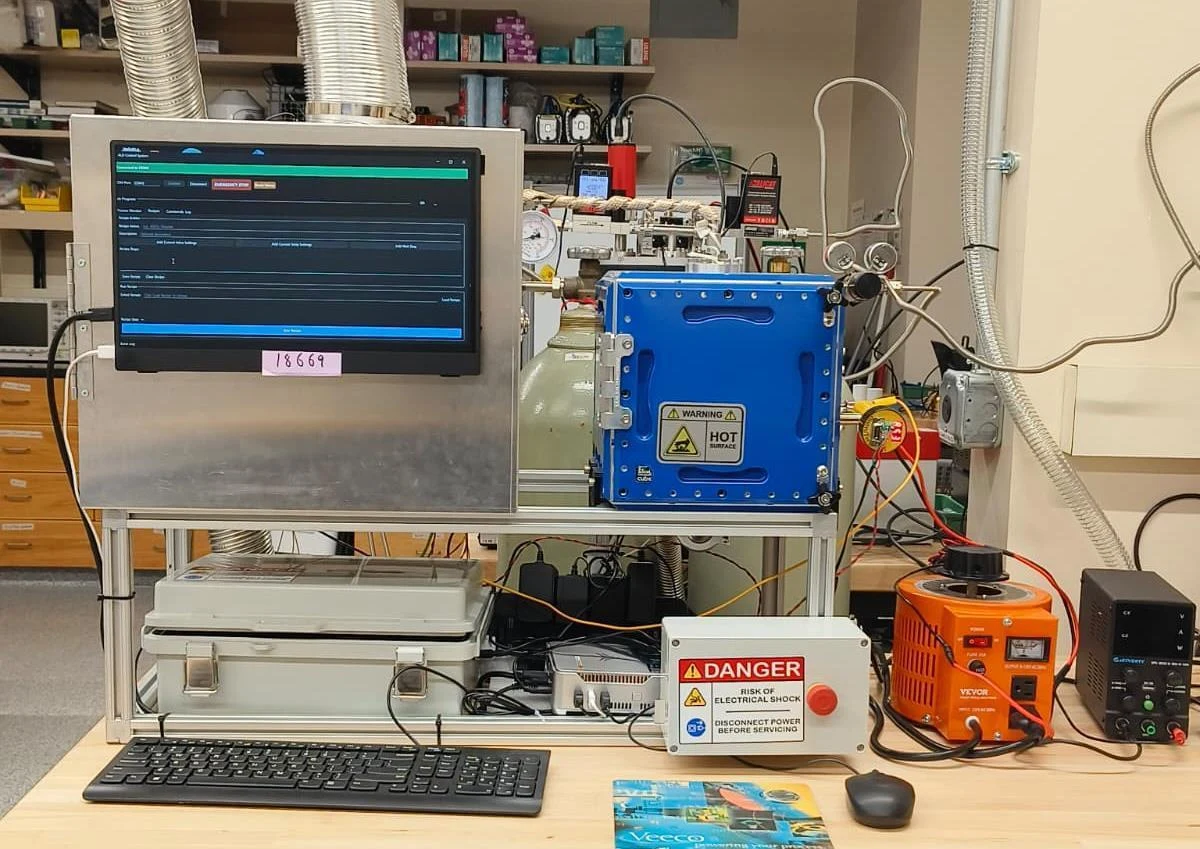
Integrating heat, vacuum, gas delivery, and automated process control.
My contributionThermal regulation, cycle automation, troubleshooting, and film characterization.
 04
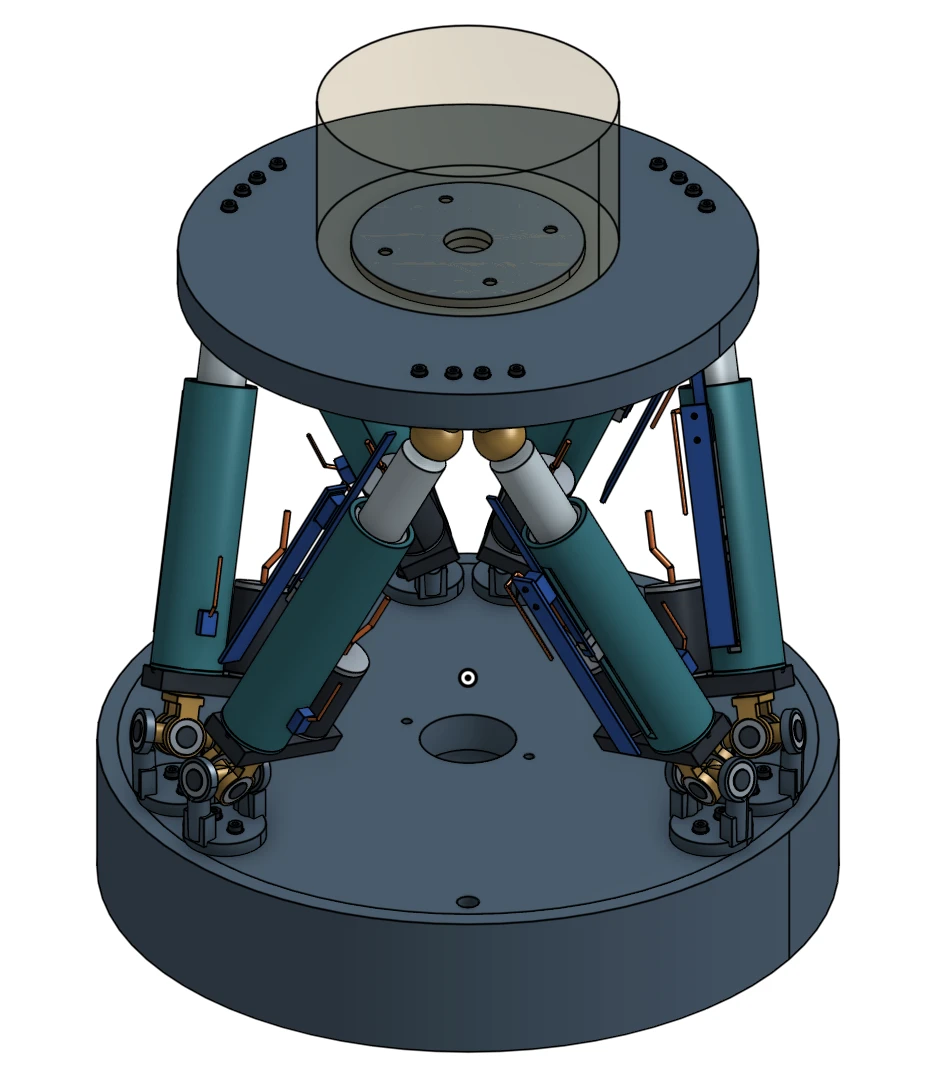
Connecting a compact six-axis mechanism to a configurable geometry optimizer.
My contributionMechanical architecture, kinematics, structural analysis, and virtual calibration.
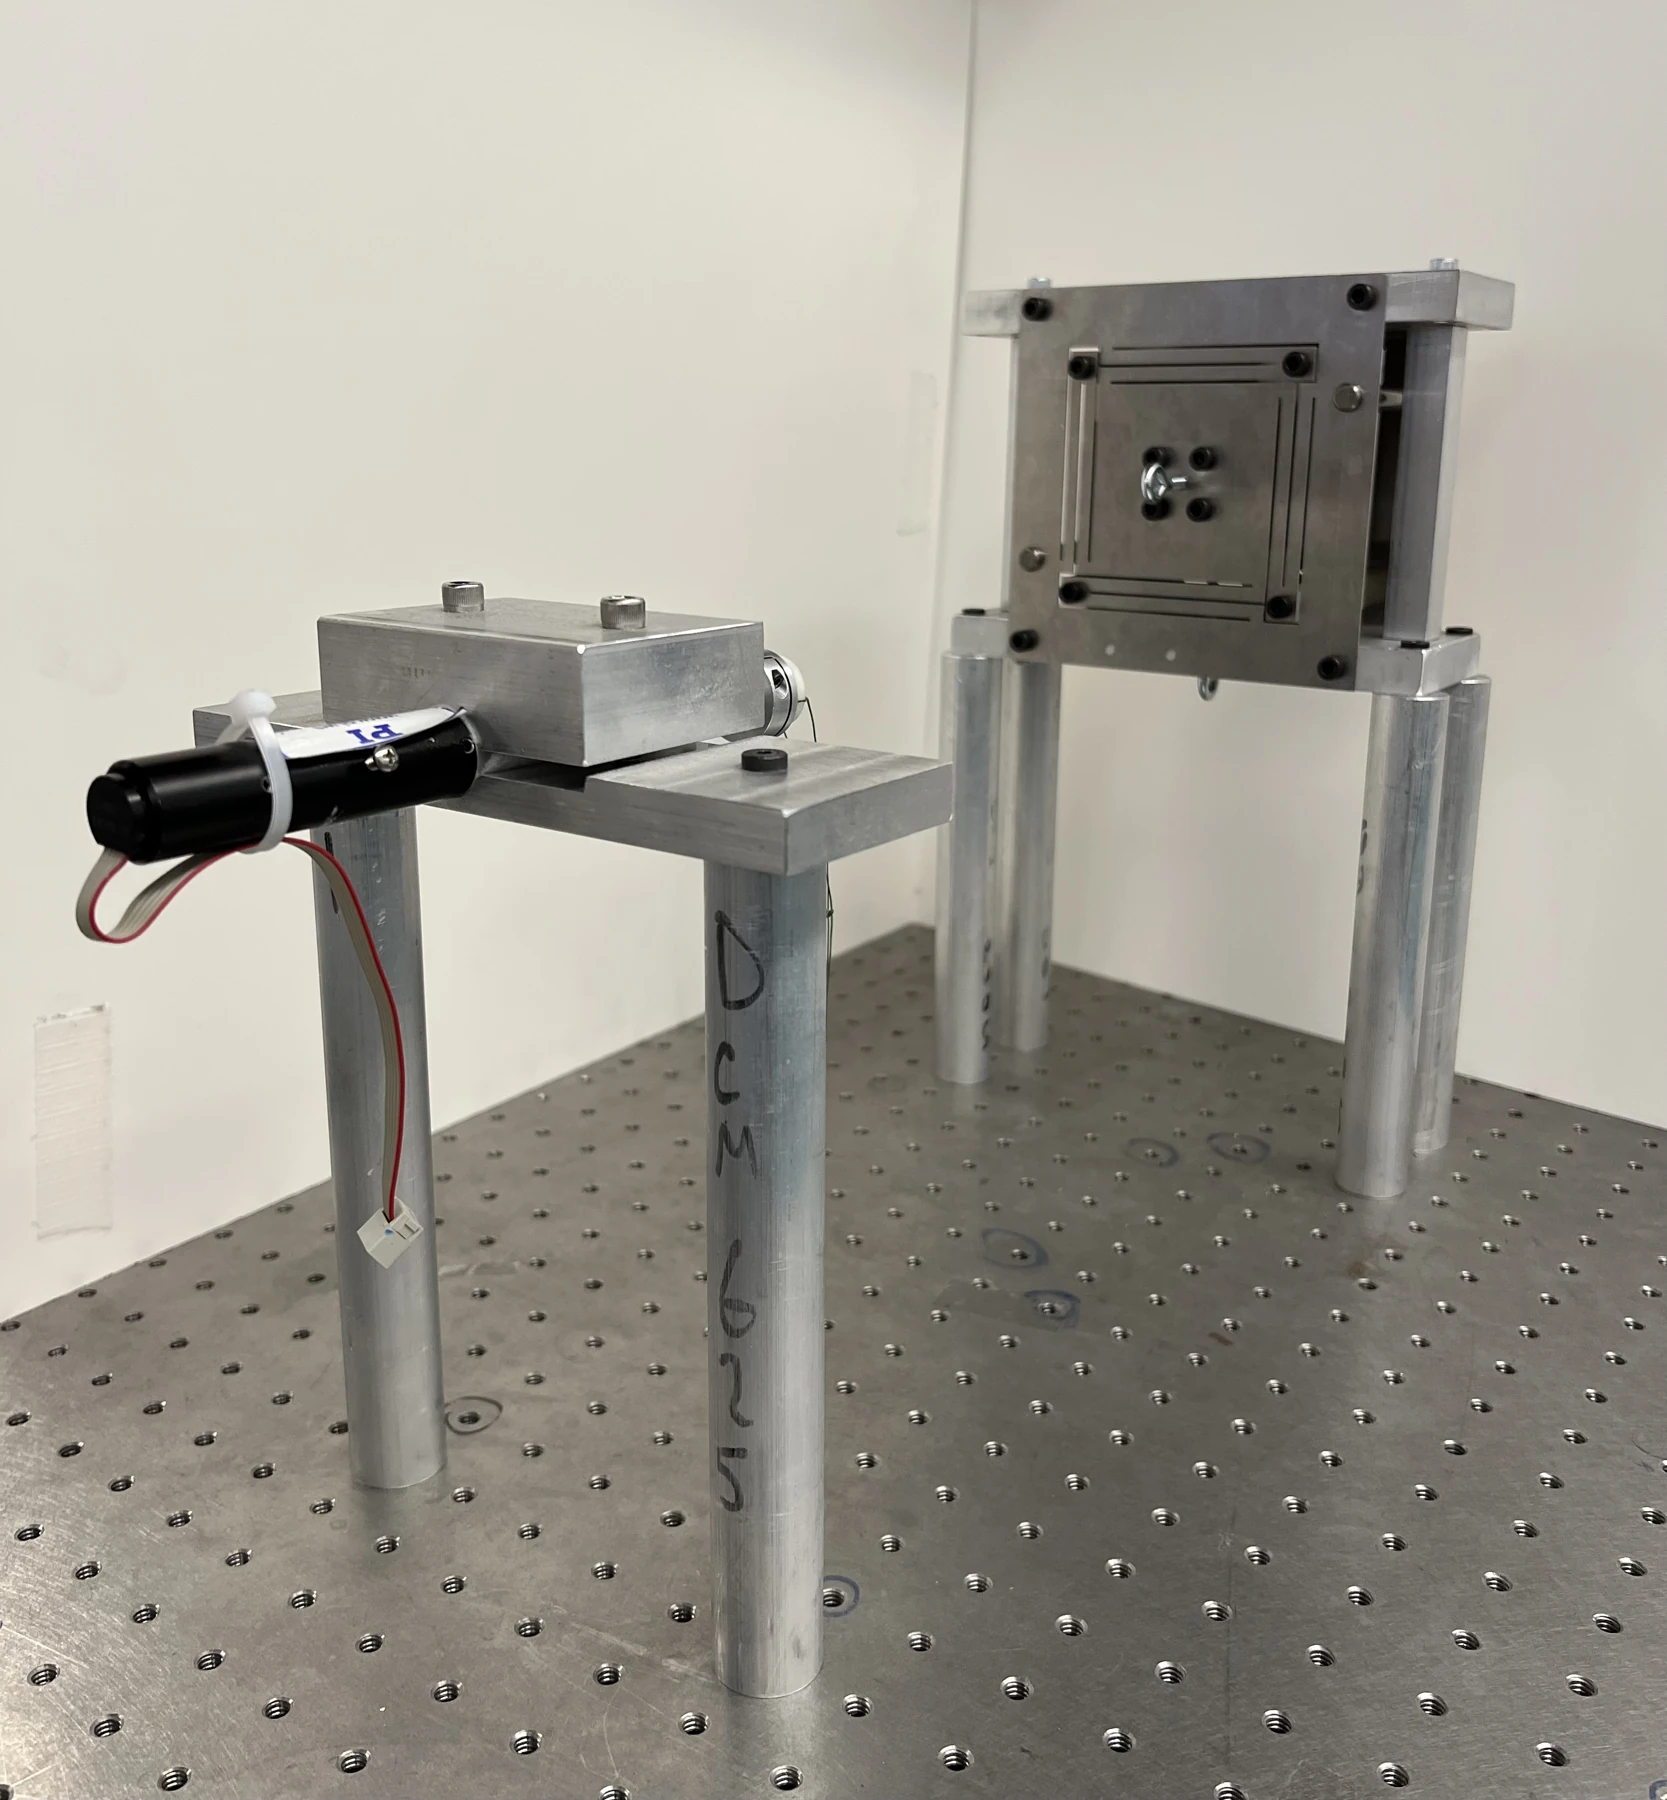 05
Turning a research flexure into an aligned, instrumented test assembly.
My contributionCAD refinement, fabrication planning, assembly, and stiffness testing.
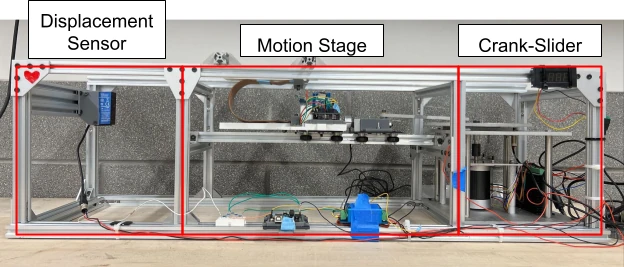 06
Characterizing rolling-loop behavior during rapid stage motion.
My contributionCrank-slider fixture design, construction, and integrated testing.
I design hardware, model its behavior, and test it against measurements.
About me