ORIGAMI ROBOTICS / ROBOTICS INTERN
Design and Prototyping of 6-DOF Arm & Autonomous Mobile Base
I designed and prototyped a modular six-axis arm and a gearbox with ≈20 arcmin backlash, and integrated sensing and motion-command workflows on an omnidirectional mobile base.
My roleArm design and fabrication, custom gearbox development, and Jetson Nano / ROS2 mobile-base integration.
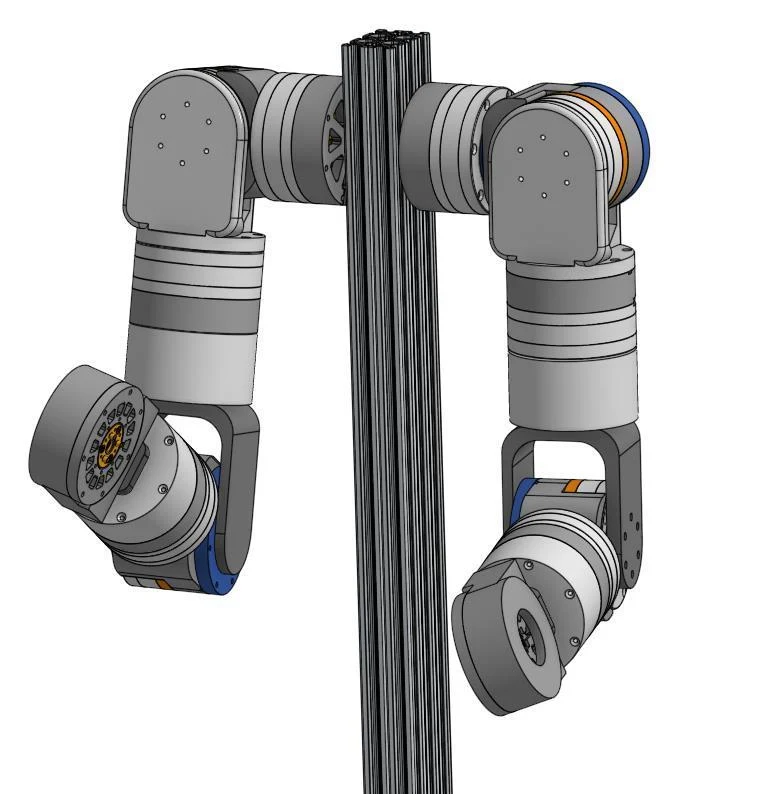
01 / ENGINEERING PROBLEM
Compact actuation and a mobile platform
The arm needed compact, cost-efficient joints that could be fabricated and assembled as modular units. In parallel, the mobile base needed onboard computing, sensing, and reliable motion commands to support autonomous navigation. My work connected mechanical prototyping with the electronics and software needed to operate the hardware.
02 / METHODS & DEVELOPMENT
Design, prototype, and integrate
Click images to enlarge
Build the arm around modular joints
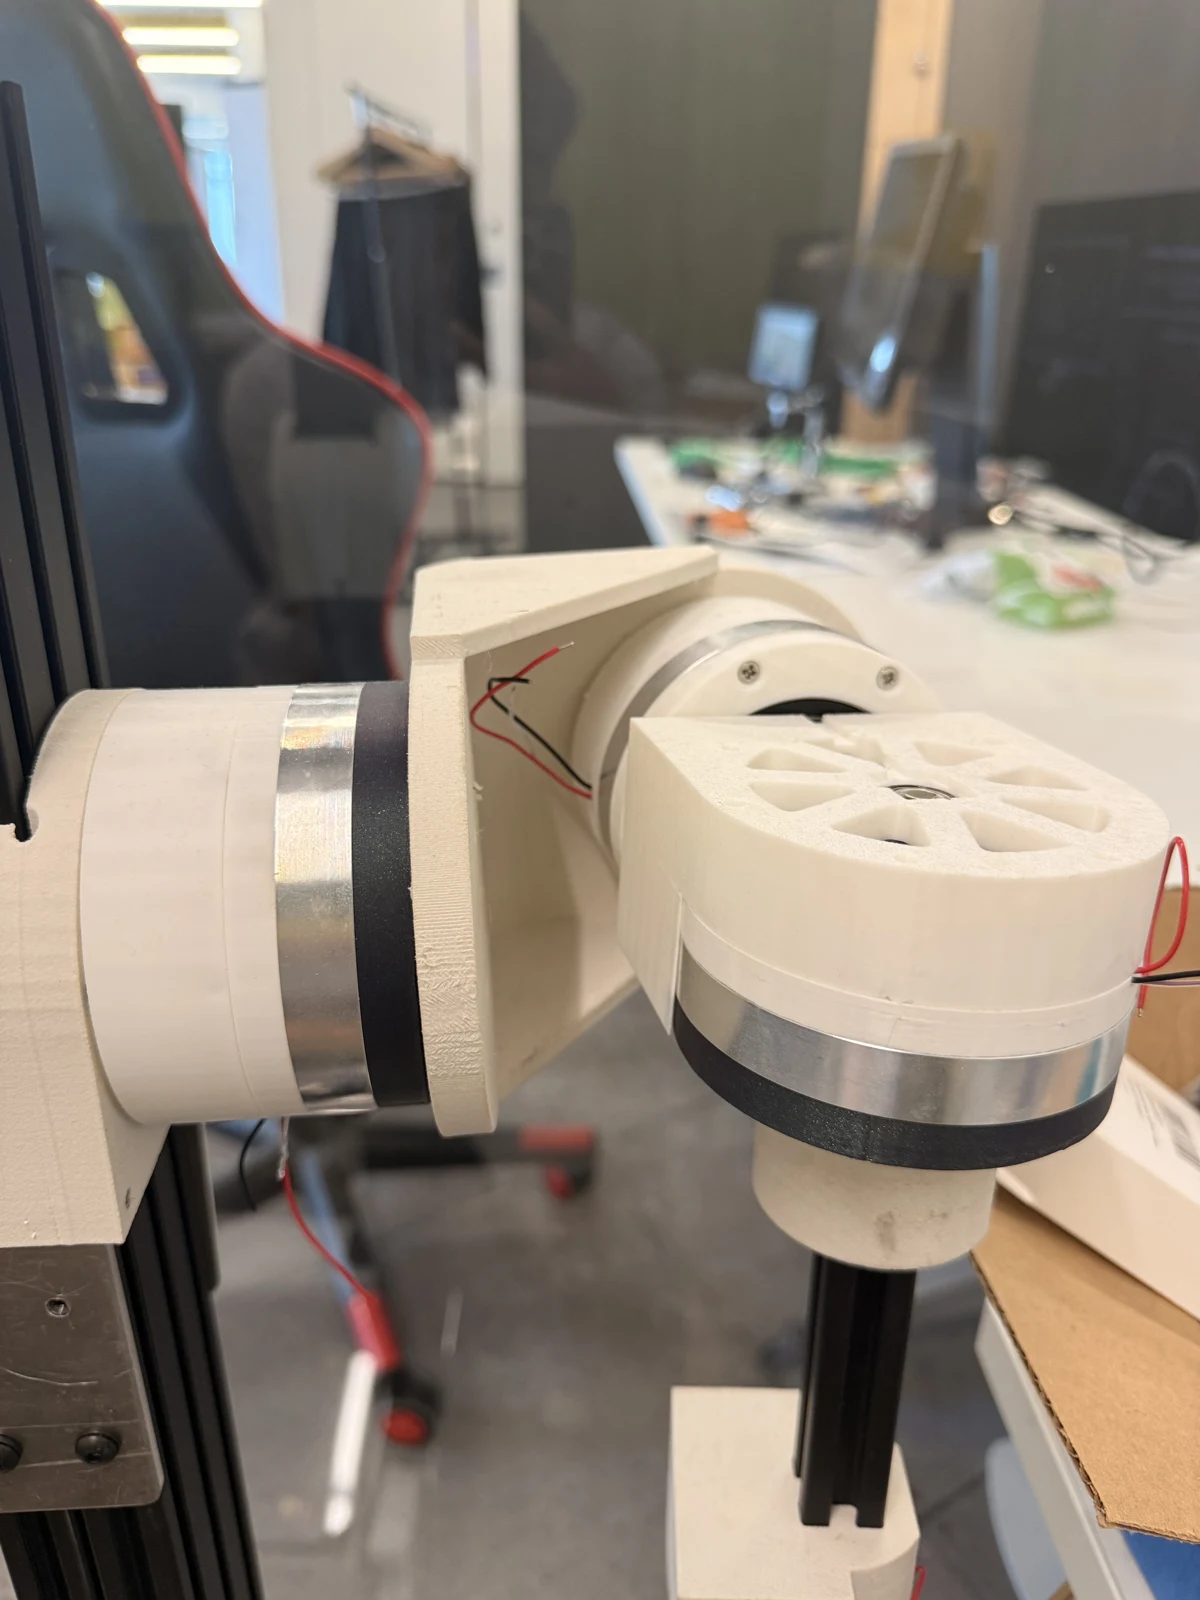
CAD → fabrication → assembly
Printed housings and CNC components
Integrated motors and transmissions
Modular joint assemblies
Develop the custom transmission
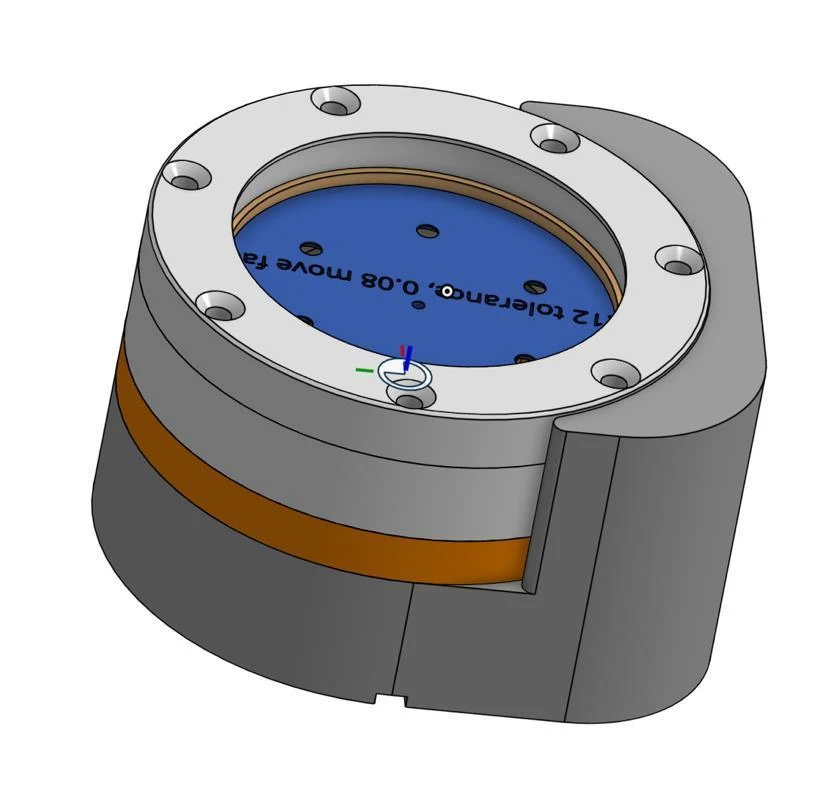
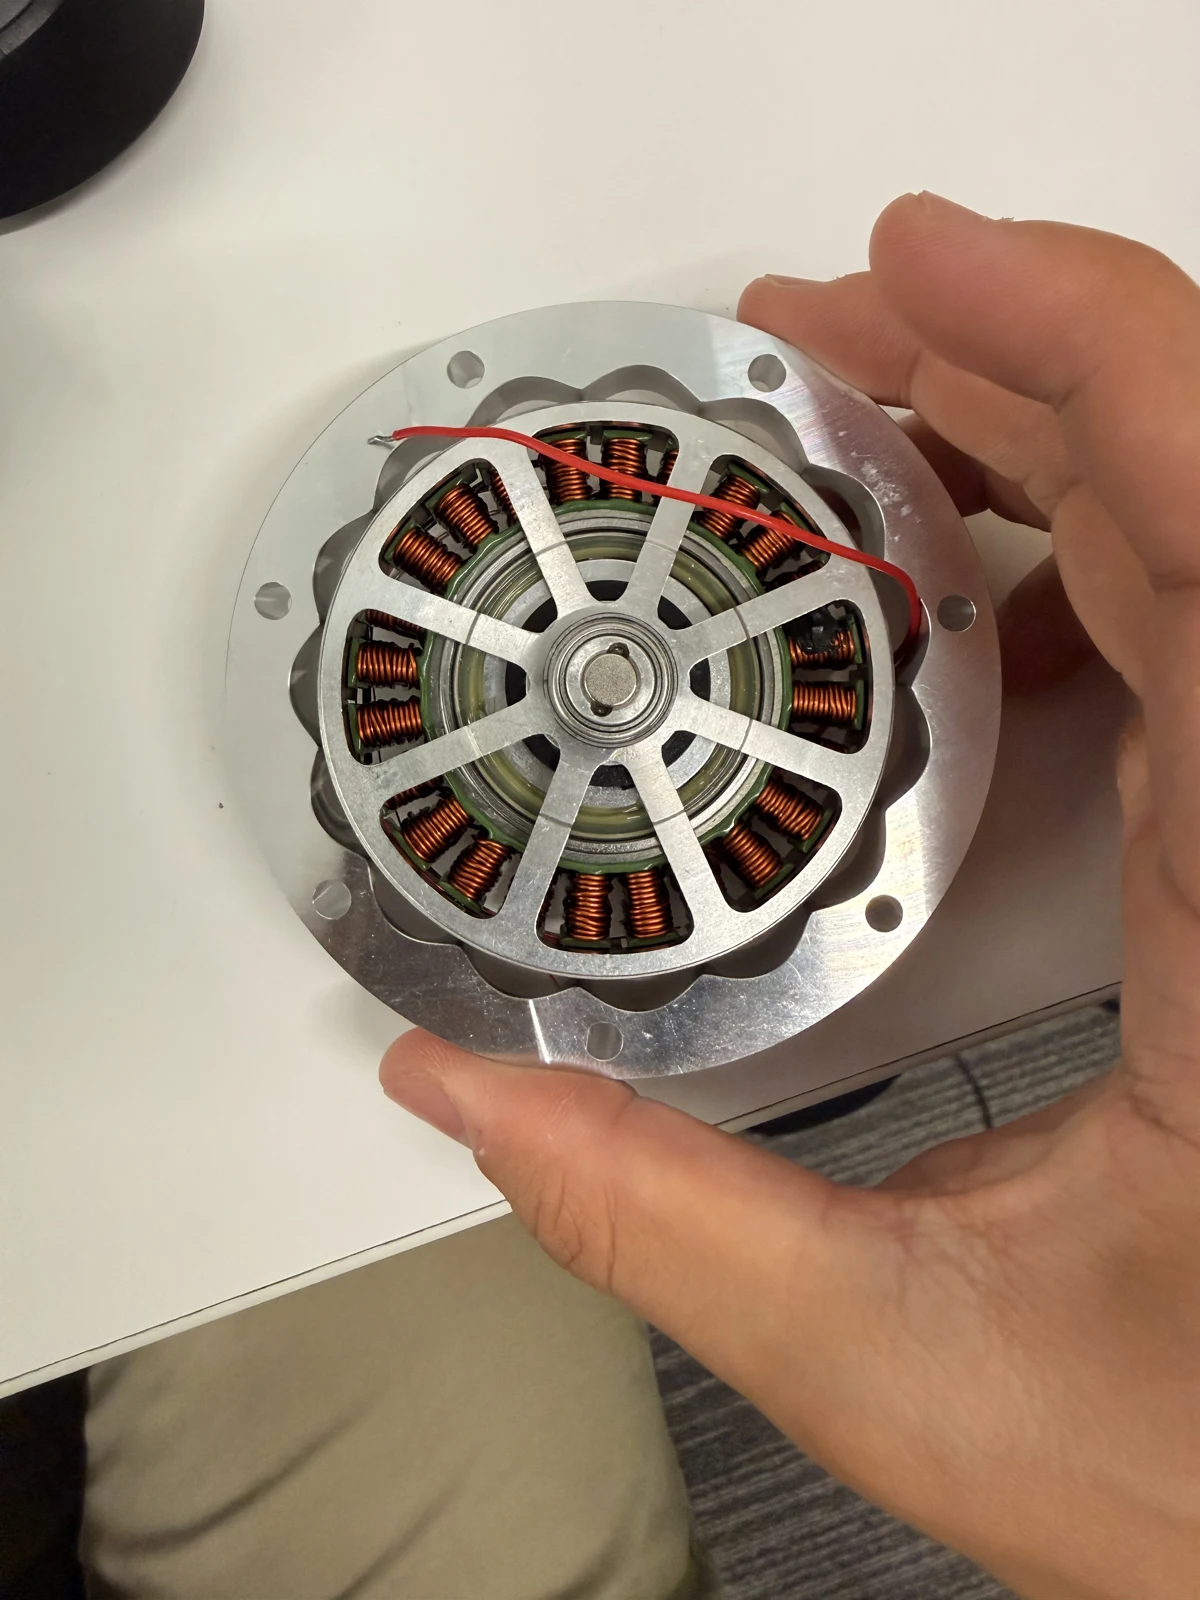
Connect sensing to mobile-base commands
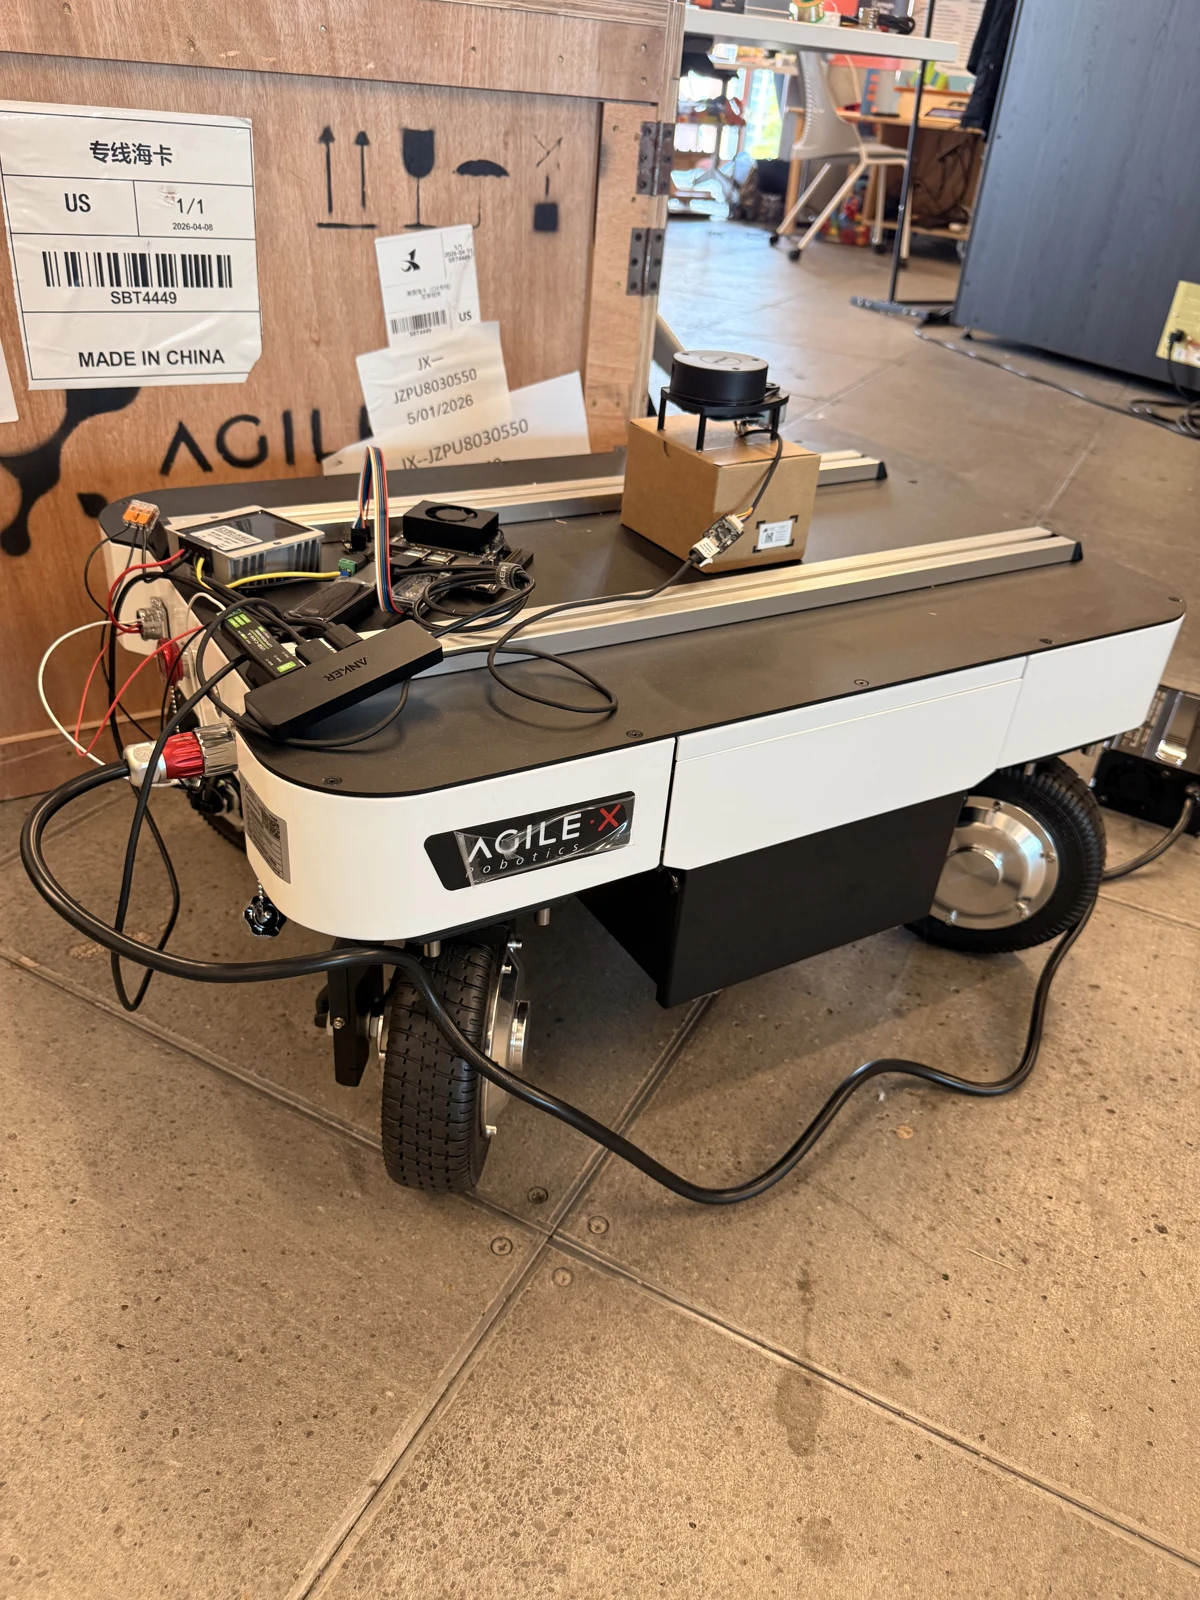
Mobile-base integration
LiDAR → onboard sensing
Jetson Nano + ROS2 → command handling
CAN → base communication
Teleoperation + pose commands
03 / RESULTS & OUTCOME
Custom hardware and an operating base
The work produced modular arm prototypes, a custom low-backlash transmission, and an integrated mobile-base control setup. Gearbox backlash describes the transmission, not end-effector positioning accuracy. Mobile-base results cover sensing, teleoperation, and pose commands; broader autonomous-navigation performance was not quantified.