UNIVERSITY OF MICHIGAN / UMARV / 2024
UMich Autonomous Robotic Vehicle Team
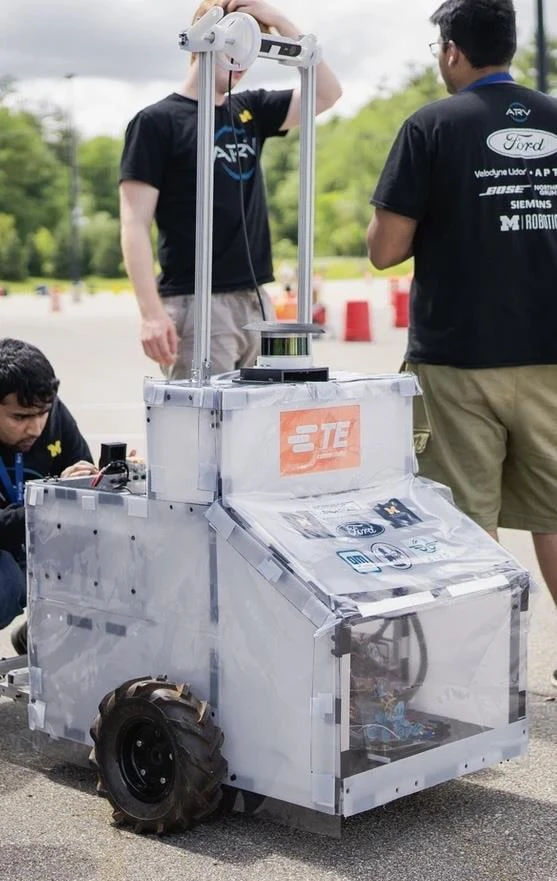
I co-led mechanical development of mARVin, contributing to a drivetrain and chassis redesign that supported a reported 60% power-efficiency improvement and a third-place team finish.
My roleVehicle development co-lead; drivetrain, chassis, and sensor-integration hardware.
01 / ENGINEERING PROBLEM
Build the hardware around the mission
The team needed an autonomous ground vehicle that combined an efficient drivetrain with a chassis capable of carrying its sensing and computing hardware. My focus was the mechanical platform: how it moved, how the hardware fit together, and how the sensors were supported for competition.
02 / METHODS & DEVELOPMENT
Chassis, drivetrain, and sensor integration
Click images to enlarge
Develop the vehicle layout
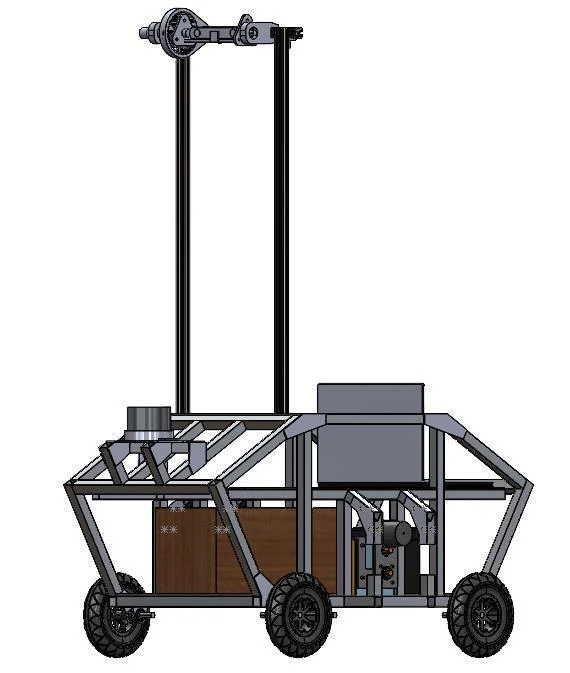
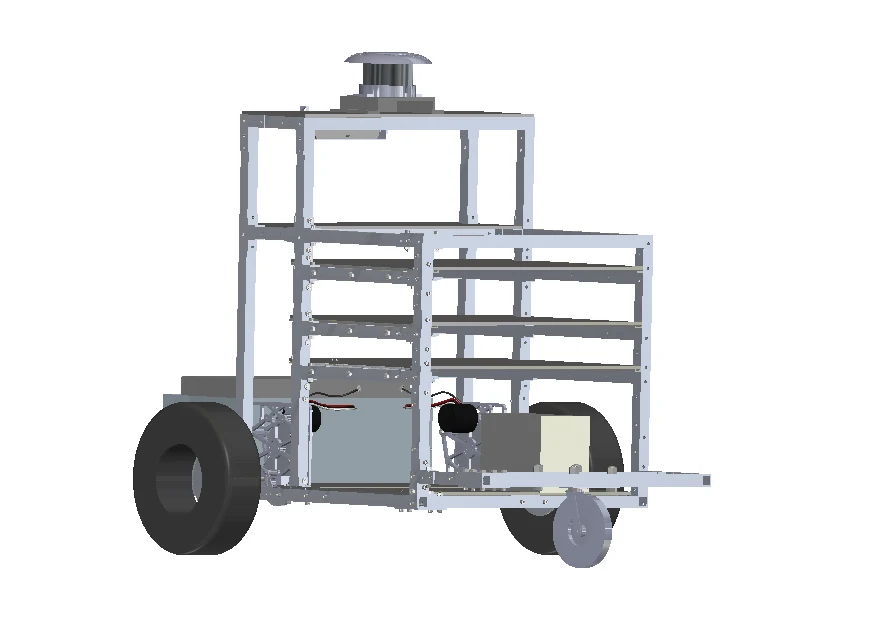
Mechanical platform
Drivetrain and chassis development
System integration
Mounting and support for sensors
Team delivery
Integrated vehicle for competition
03 / RESULTS & OUTCOME
A competition-ready team platform
The team reported a 60% improvement in power efficiency and a third-place competition finish. My contribution was the drivetrain, chassis, sensor-support hardware, and coordination of platform development. These are combined team outcomes, rather than isolated measurements of any one component.