ROBOTICS STARTUP / PRODUCT DEVELOPMENT INTERN / 2024
Packaging System for Robotic Device
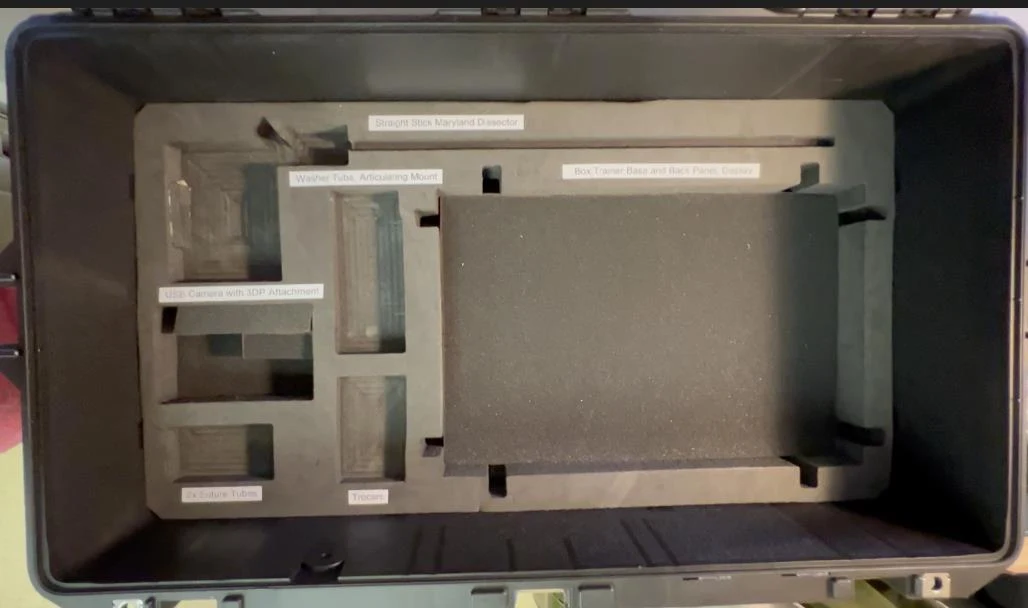
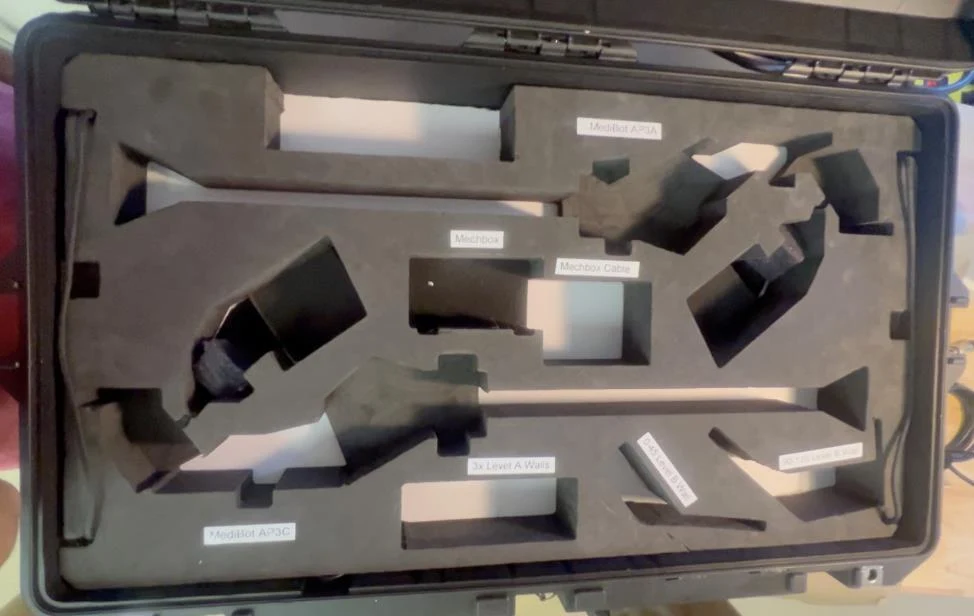
I designed and manufactured compact packaging configurations that restrained a robotic device’s multi-axis motion and organized its components for air and land transport.
My roleSolidWorks design, motion-constraint analysis, CNC-routed and printed prototypes, and design-review documentation.
01 / ENGINEERING PROBLEM
Restrain the device within a compact case
A robotic device’s moving parts needed to be supported during transport while its components and accessories fit into a compact case. I evaluated how to restrain the device’s multiple degrees of freedom, then developed packaging configurations that could be manufactured and checked as physical prototypes.
02 / METHODS & DEVELOPMENT
From constraint layout to physical packaging
Click images to enlarge
Design and prototype the internal layout
Define restraint
Analyze the device’s possible movement
Make and check
Fabricate and iterate the packaging
Document decisions
Phase-gate reviews and design reports
03 / RESULTS & OUTCOME
Manufactured packaging prototypes
I delivered transport-packaging prototypes and documented the design iterations through phase-gate reviews and design reports. The outcome demonstrates constraint design, fabrication, and prototype refinement; no quantified drop, vibration, or shipping qualification is claimed.